

Pick and Place Using Peter Corke Toolbox MATLAB
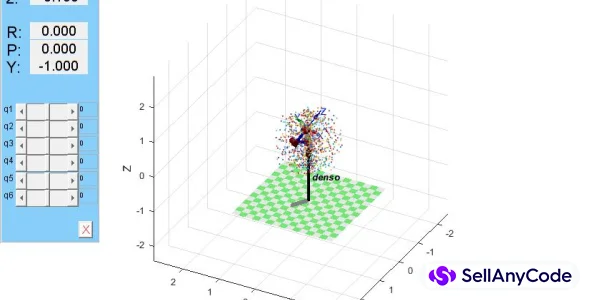
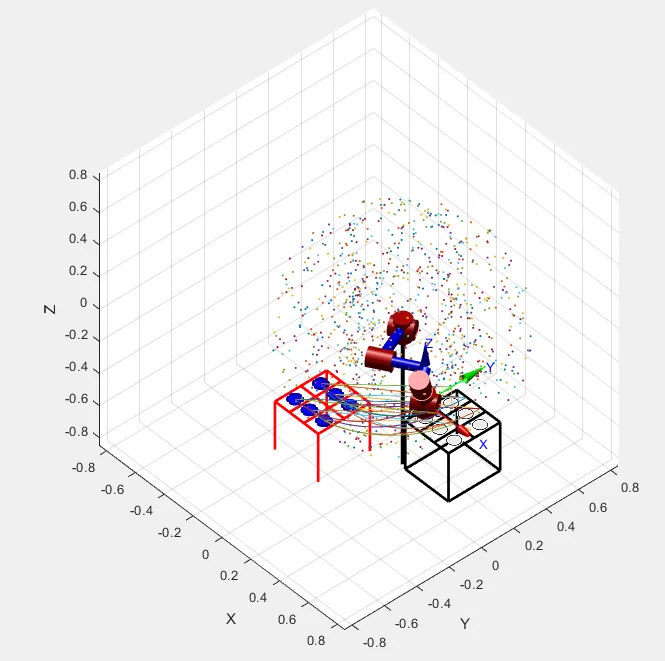
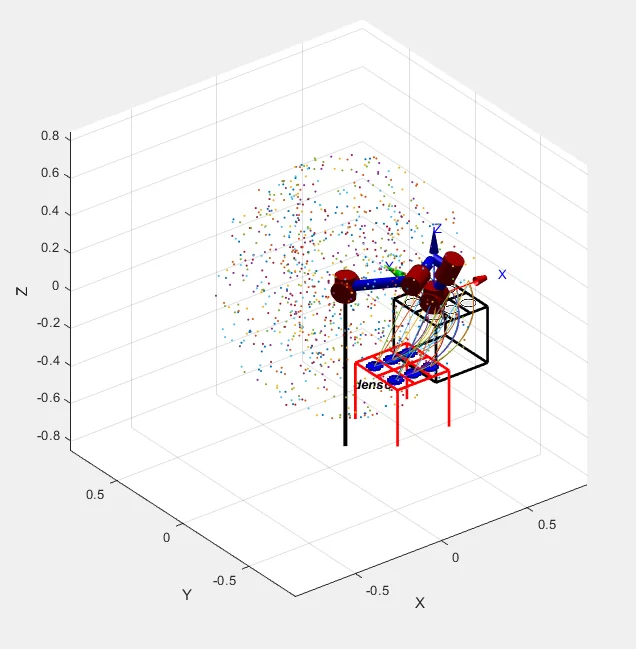
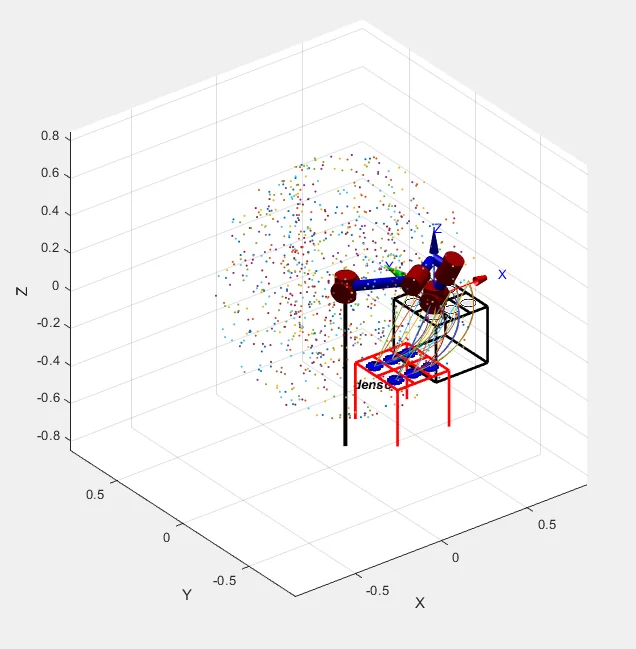
generating of the workspace of the robot arm, pick and place
Item Description
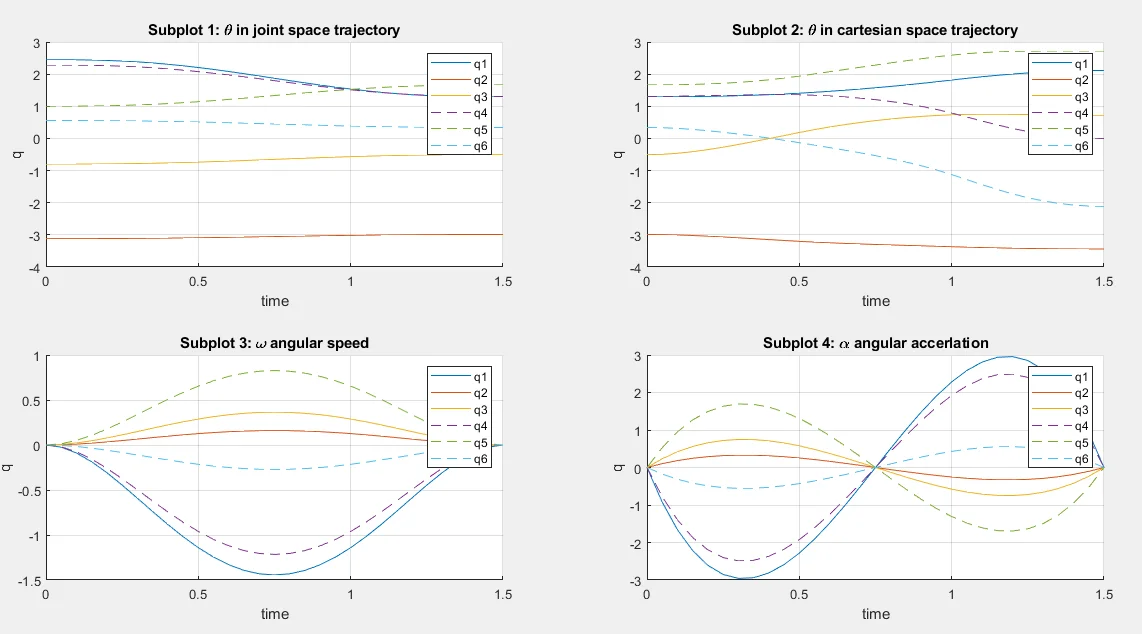
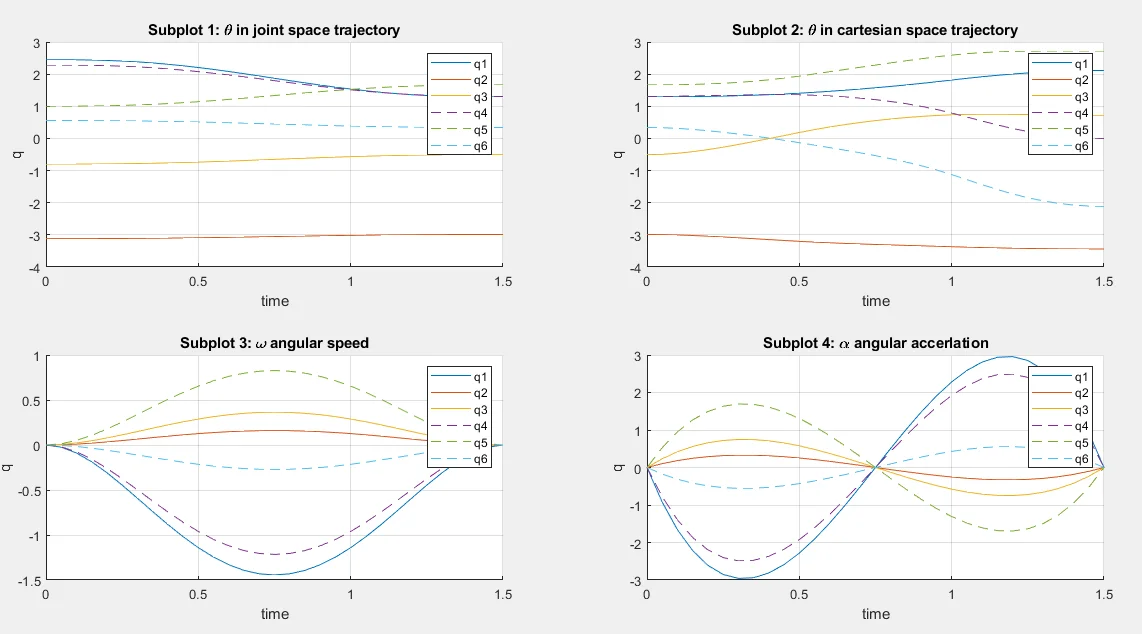
This script represents the generating of the workspace of the robot arm, in which it depends on the dimensions of the arm( in other word dh table). It also represents the pick and place of its two different ways :forward kinematics and inverse kinematics
Features
MATLAB, Robotics Toolbox by Peter Corke
$ 25
- Verified source code
- Join 35191+ buyers which trust us!
- Download code immediately

100% Guarantee For Item!
Satisfaction guarantee policy.
Satisfaction guarantee policy.
Information
| Category | Scripts & Code / VB.NET |
| First Release | 29 August 2024 |
| Files included | .m |
| File Size | 4 MB |
| Frameworks | VB.NET |
Similar Items